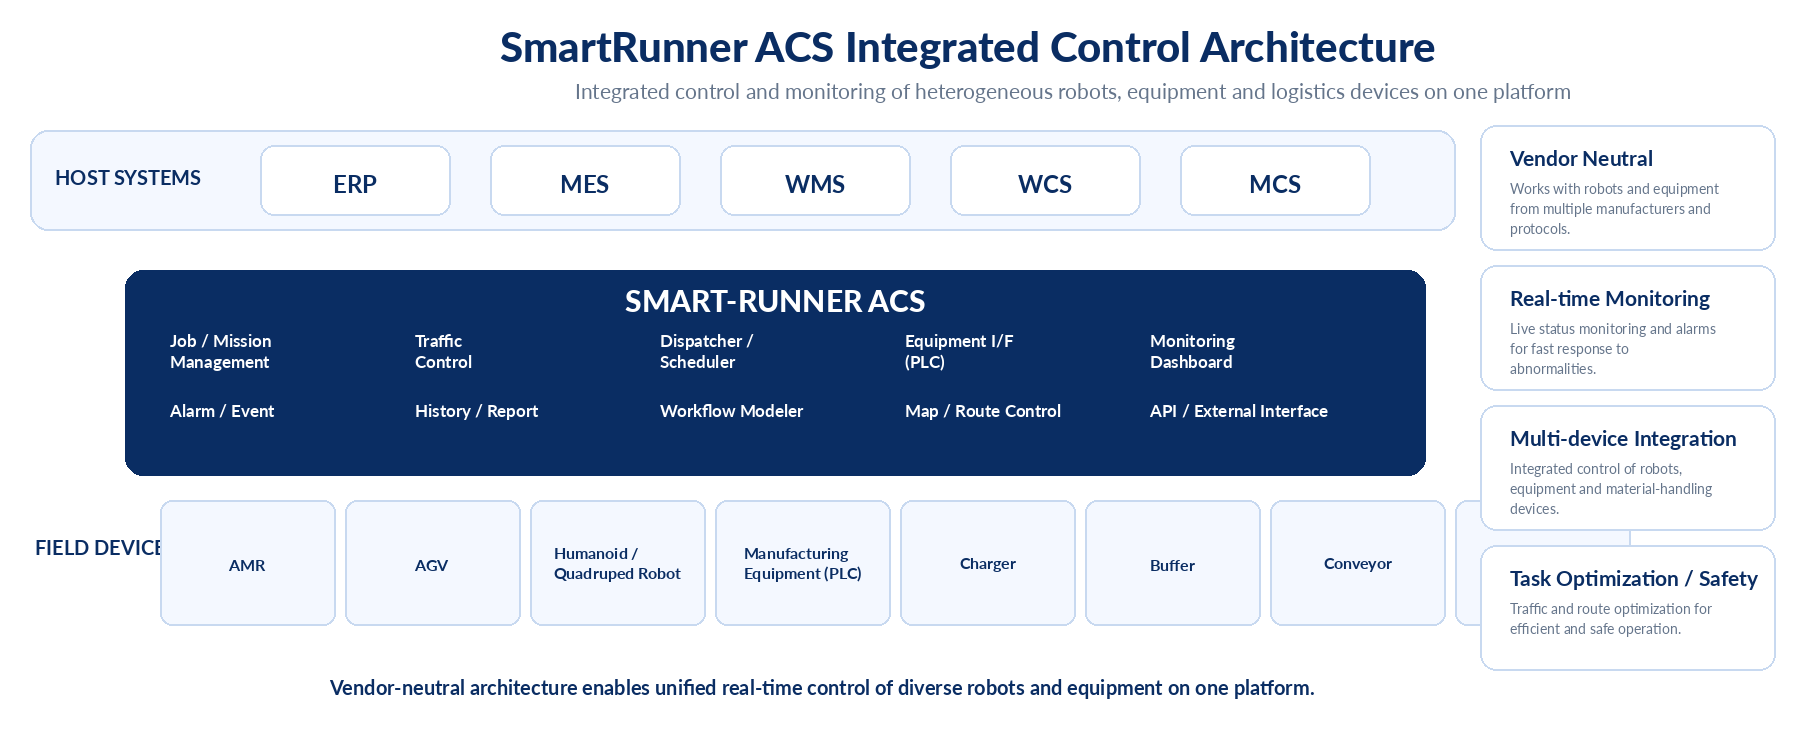
A Vendor Neutral AMR integrated control system (ACS) that monitors and controls heterogeneous AMRs/AGVs and automation equipment across factories and distribution centers in real time from a single screen, and links directly with higher-level production and logistics systems (MES/WMS/WCS) to deliver commands down to the equipment level.
Vendor Neutral robot & equipment integration
Optimal traffic & priority for many AMRs
Real-time I/F with MES·WMS·WCS·MCS
Real-time dashboard & reports
Integrated control of heterogeneous robots and equipment under a single framework, regardless of manufacturer.
Control heterogeneous robots from any manufacturer under one framework
Synchronize production and logistics data with host systems via standard I/F
Integrated operation of AMRs, AGVs, humanoids and more
Users design work flows directly, without any coding
Visualize robot, equipment and task status on a single screen
Handle collision/bottleneck prevention and equipment safety interlock together
Automatic recovery via standard scenarios when anomalies are detected
Rapidly onboard new robots and equipment with a modular structure
Controls inter-line material transport in conjunction with MES. Real-time management of equipment interlock and process load/unload. Semiconductor · Display · Secondary battery · Automotive parts
Automates inbound/outbound, picking and transport in conjunction with WMS/WCS. Optimal traffic and priority control for many AMRs. Distribution centers · Fulfillment centers
Integrated operation of service robots for guidance, delivery and patrol. Linkage with infrastructure such as elevators and automatic doors. Offices · Hospitals · Public institutions · Commercial facilities
* Position accuracy is based on SmartRunner AMR specifications; other figures are design targets and may vary depending on the customer environment.
| Comparison Item | SmartRunner ACS | Company O (overseas) | Company M (overseas) | Company C | Company S | Company Y |
|---|---|---|---|---|---|---|
| Heterogeneous robot control (Vendor Neutral) | ◎ | △ | △ | ◎ | ○ | ○ |
| Real-time MES/WMS·WCS linkage | ◎ | ◎ | ◎ | △ | ○ | △ |
| Manufacturing equipment I/F (PLC/Interlock) | ◎ | ○ | △ | △ | ○ | △ |
| Traffic Control / collision avoidance | ◎ | ◎ | ◎ | ○ | ○ | ◎ |
| No-code Work Flow / scenarios | ◎ | △ | △ | △ | △ | △ |
| Humanoid / quadruped extensibility | ◎ | ✕ | ✕ | △ | ✕ | ✕ |
| Domestic SI · customization support | ◎ | △ | △ | ◎ | ◎ | ◎ |
| On-premise deployment support | ◎ | ○ | ○ | ○ | ◎ | ◎ |
◎ Excellent · ○ Supported · △ Limited · ✕ Not supported | Based on public websites/brochures as surveyed in July 2026, including LoadRunner's own feature definitions.
A next-generation control architecture based on Agentic AI, under development as a government-funded national R&D project (May 2026 – Dec 2027, 20 months). A pilot is planned with a semiconductor R&D FAB demonstration partner.
LLM (32B-class) + LoRA fine-tuning + RAG · a multi-agent structure of Dispatcher/Router/Planner aiming for "Zero-SI".
Edge inference based on a lightweight sLLM (4B-class) · real-time local decisions and natural-language command processing on low-power CPUs.
Standard/non-standard protocol plugins such as AMR, ROS, MAVLink, PLC and MES · 3D Gaussian Splatting spatial awareness.
We provide ACS consultations and demos.